Arduino Bluetooth Controlled Car
Level 14 · Level 14 — Remote Control · 30 minutes
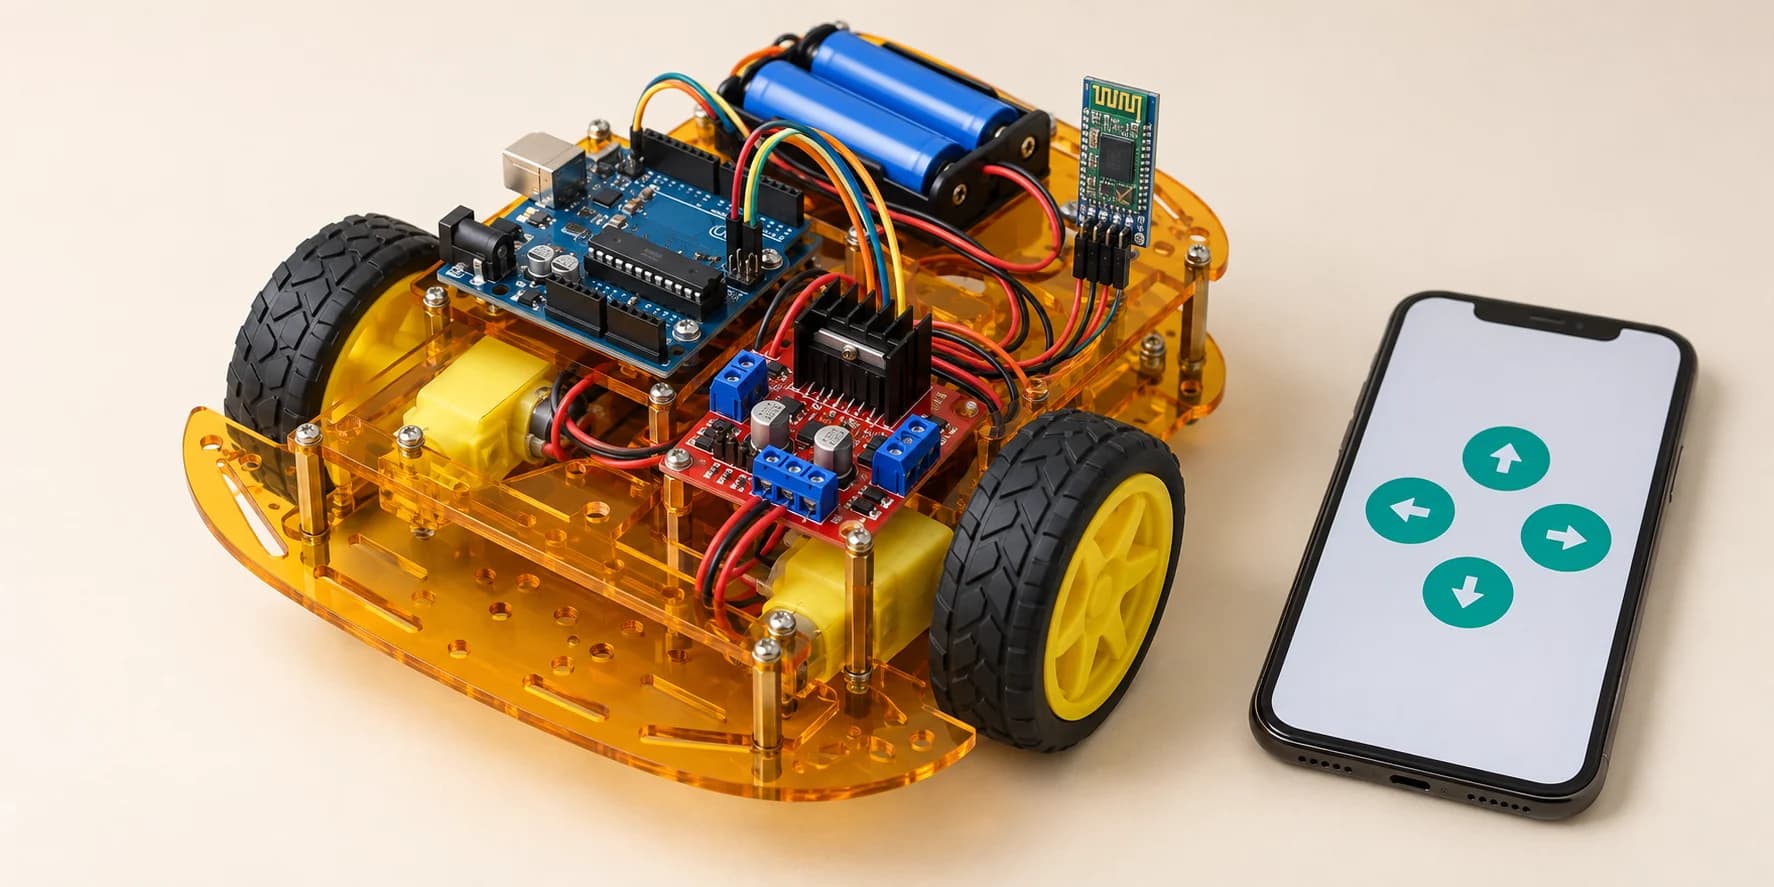
A robot your phone drives, over a Bluetooth link that is really just a serial cable.
Preview the project free; a course seat is required to run and submit. No hardware kit needed.
Your project challenge
Make the robot obey your phone. Keep Level 9's car, add the Bluetooth module: - VCC to 5V, GND to GND - TXD to D0, the board listens there - RXD to D1, the board's TX F, B, L, R start driving. f, b, l, r stop. A right turn: left wheel forward, right wheel back. Left mirrors it.
Components you’ll use
- Arduino Uno
- L298N Motor Driver
- DC Gear Motor × 2
- Battery
- HC-05 Bluetooth Module
What you'll build
A car your phone drives around an empty room. One letter starts it, another stops it.
Bluetooth is a wireless serial cable
- The blue module does not understand "forward". It understands nothing.
- It is a wire that happens to have no wire in it.
- Letters land on
Serialexactly as the USB lead's do. The Serial Monitor's send box is the phone. - So there is no Bluetooth to program. Only
Serial.read().
TX goes to RX
The module TALKS on TXD, the board LISTENS on D0: TXD to D0, RXD to D1 (the board's TX).
The key idea
Uppercase starts, lowercase stops: F B L R drive, f b l r stop.
- The letter arrives once and is gone.
- A command does not drive the wheels. It sets what the robot should be doing;
loop()drives. - Read the letter, remember it, act on the memory.
- A right turn is a spin: left wheel forward, right wheel back. Left mirrors it.
⚠ Watch out
Wire TXD to D1 and RXD to D0, and nothing arrives. The robot sits still. Real hardware stays silent; here an amber card appears, starting TXD is not connected to D0…
The interactive editor includes the wiring guide, code editor and simulation controls.