Arduino Robotic Arm with Four Servos and Two Joysticks
Level 56 · The Arm · 35 minutes
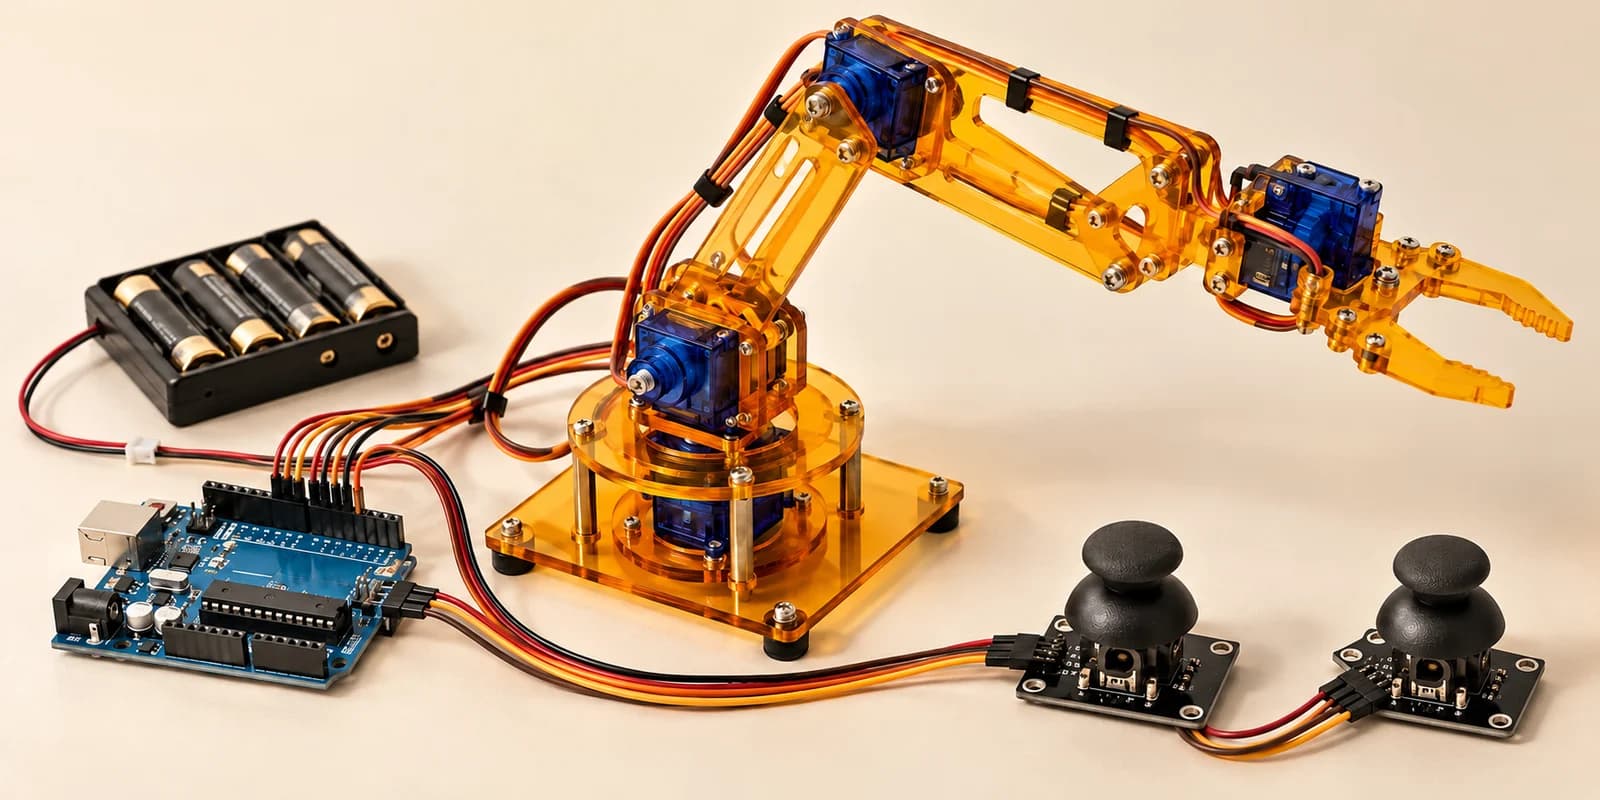
Control a four-servo arm with two joysticks: turn, lift, bend and open or close the gripper. Release either stick to hold.
Preview the project free; a course seat is required to run and submit. No hardware kit needed.
Your project challenge
Use two sticks. Left: turn and lift. Right: left/right closes/opens the gripper; up/down bends the elbow. Release to hold. Move about 100°/s within the limits. Follow all 21 wiring steps. SW pins are unused.
Components you’ll use
- Arduino Uno
- SG90 Micro Servo × 4
- Joystick (KY-023) × 2
- Battery
What you’ll build
A four-joint robotic arm with two joysticks. Watch the assembled arm move in the 3D panel while your Arduino code drives the servos.
How it works
- Left stick: left/right turns the base; up/down raises or lowers the shoulder.
- Right stick: up/down bends the elbow; left closes the gripper and right opens it.
- Release either stick to hold that position. No click is needed. Leave both SW pins unused.
The key idea
Use rate control: move each joint a little every loop. A dead zone stops drift when the sticks rest near the centre. Limits keep the joints within their working ranges.
⚠ Watch out
Power the servos from the battery and share ground with the Arduino. If you restored an older version, reset to this starter and follow the updated wiring guide.
Make it yours: try holding the gripper halfway open.
The interactive editor includes the wiring guide, code editor and simulation controls.